Engineering (Elektrotechniek & Werktuigbouwkunde) - Integraal Project
Robot+Positioner
Adnan Shams Eddin, Hanna Geryous Fares, Maarten Verlinden
Doel
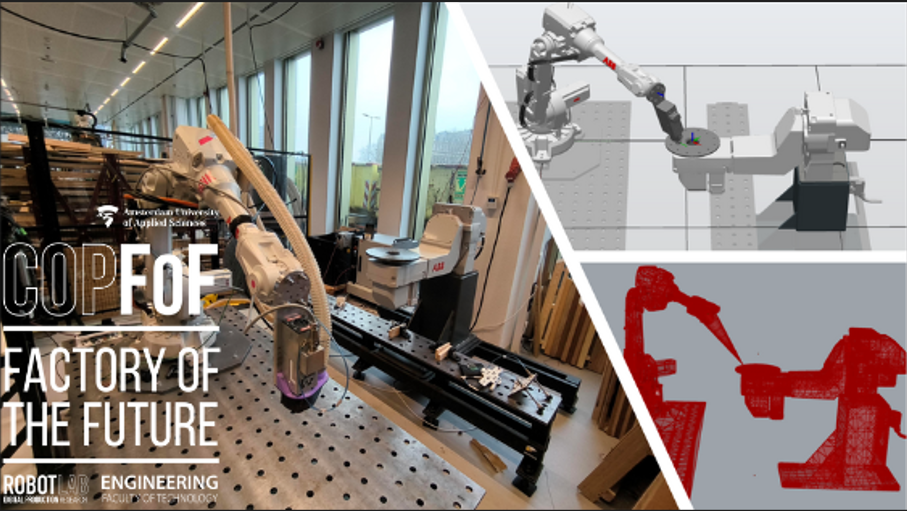
Integrate a positioner platform with a 6-axis robot to enhance production capabilities (milling) The project also aims to develop a clear user manual.
Aanpak
Research and Exploration
• Learning Robot Studio, Rhino and Documentations provided from ABB and the Robotlab.
• Learning from Industry Practices where a positioner is being use
Development and Calibration
• Calibration Process
• Documentation and Visual Records
Utilization of Robot Studio for Simulation and Execution
• Digital Twin Creation
• Simulation and Collision Detection
• Refining the Workflow
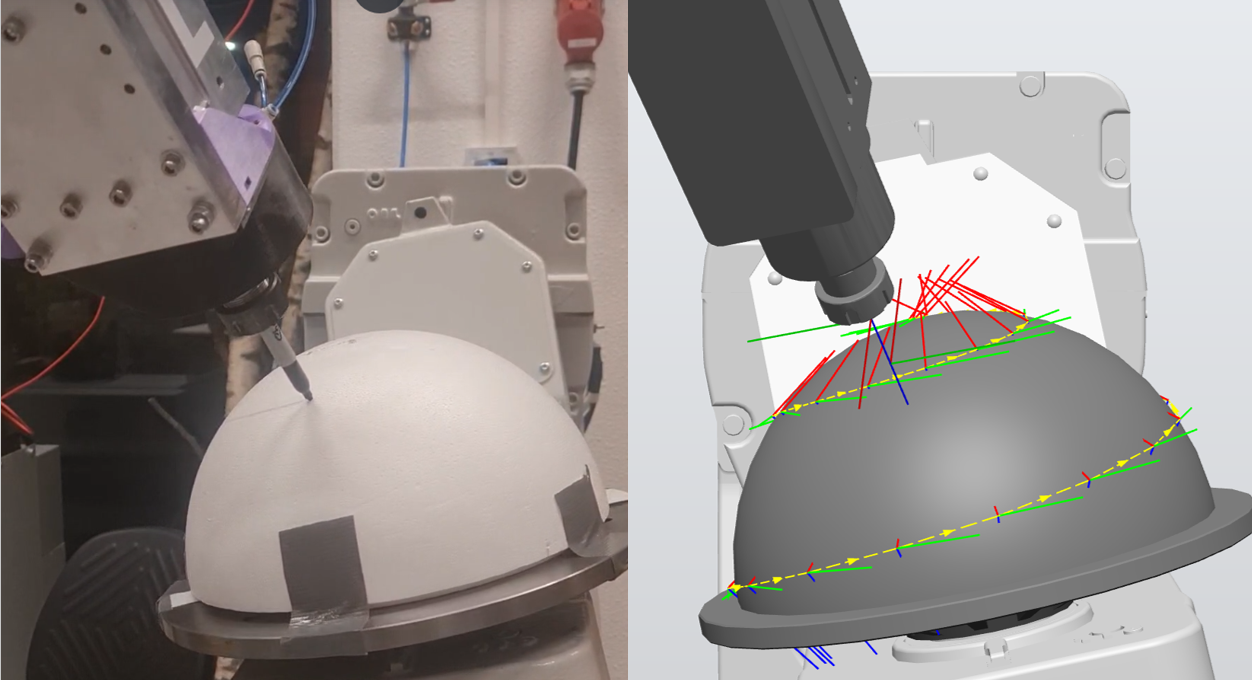
Integration with Grasshopper for Enhanced Toolpaths
• Parametric Design Integration
• Toolpath Generation and Optimization
• Transition to RAPID Code
Testing and Evaluation
• Testing
• User Manual Creation
• Learning Robot Studio, Rhino and Documentations provided from ABB and the Robotlab.
• Learning from Industry Practices where a positioner is being use
Development and Calibration
• Calibration Process
• Documentation and Visual Records
Utilization of Robot Studio for Simulation and Execution
• Digital Twin Creation
• Simulation and Collision Detection
• Refining the Workflow
Integration with Grasshopper for Enhanced Toolpaths
• Parametric Design Integration
• Toolpath Generation and Optimization
• Transition to RAPID Code
Testing and Evaluation
• Testing
• User Manual Creation
Resultaat
The project creates a universal system for positioner and 6-axis robot collaboration. and providing the digital twins files and a manual over the use of the setup.